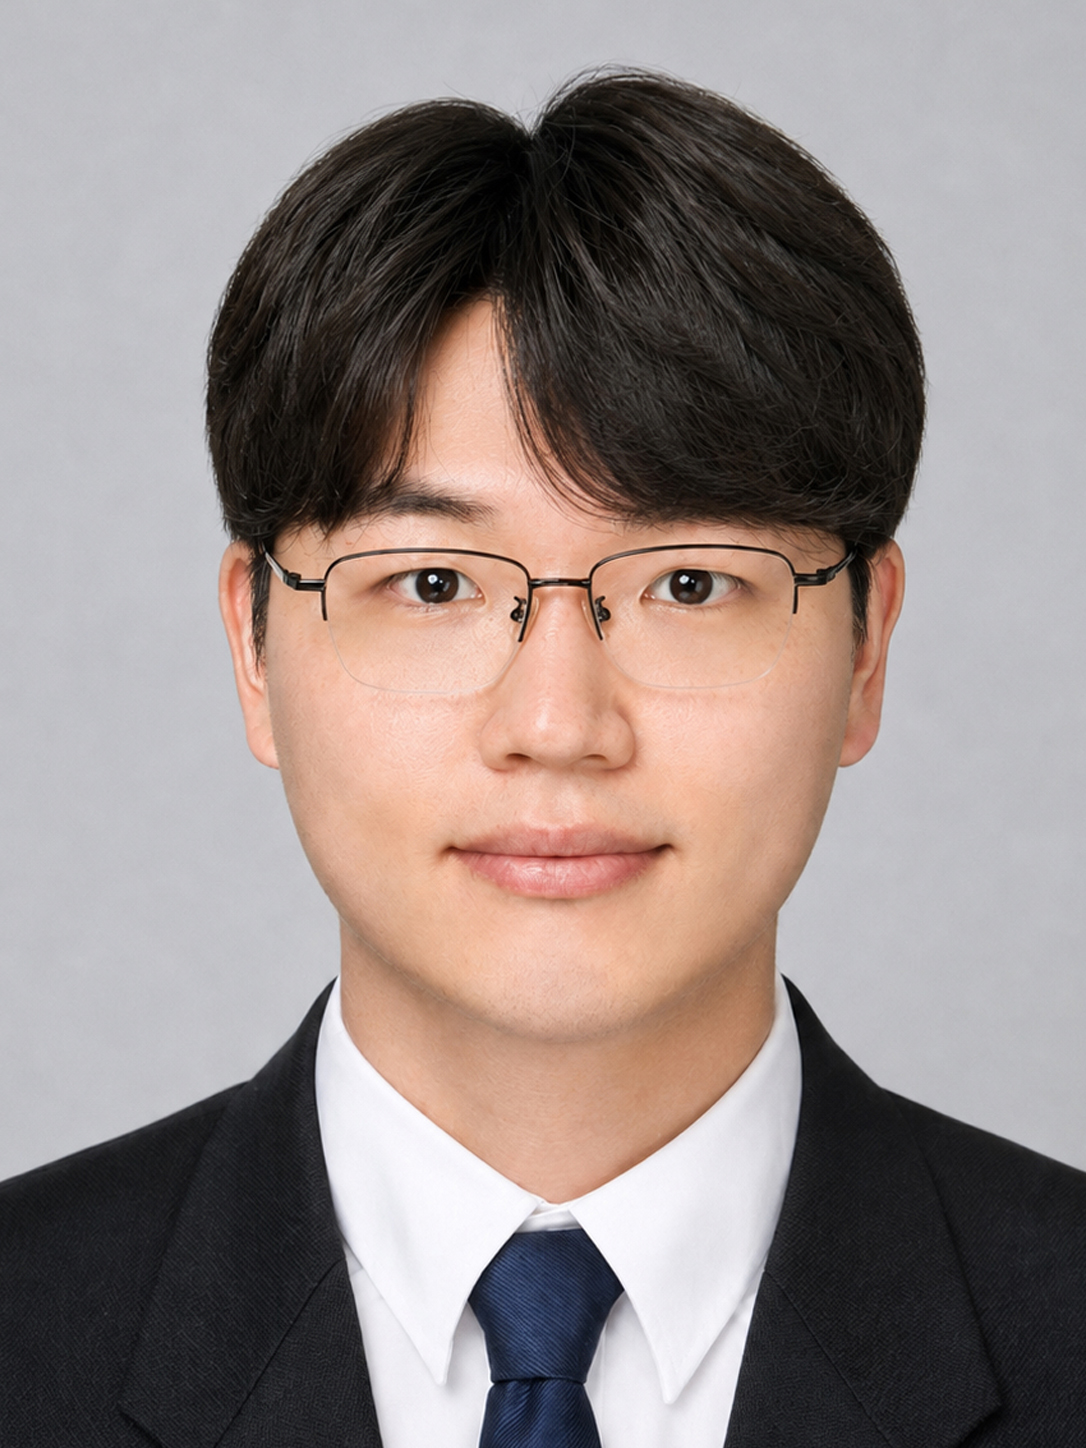
Sangho An
Start Fearlessly. Build Steadily. Finish Fully.
Undergraduate Researcher in Robot Learning
Control & Optimization Lab (COLAB) · Electrical Engineering, Hanyang University
Cumulative Rank: 2/75 (through Spring 2026, Senior Year)
Robotics · Learning · Control
I study policy learning for robotic manipulation. My current work conditions Diffusion Policy on a lightweight world model and evaluates it on a real Franka arm; I presented it orally at ICCAS 2026. With a background in electrical engineering, I also build the hardware, power, and control systems that learning-based robots rely on.
Highlights
View history- Presented “Enhancing Visuomotor Manipulation Control with a Predictive-Dynamics-Aware World-Model-Conditioned Diffusion Policy” in an oral session at ICCAS 2026. →
- Launched EIGENROOM, an interactive control-engineering lab for exploring how systems respond to controllers and disturbances. →
- 2nd Place · Energy Up! 2026 New Energy Industry Idea Lab Competition →